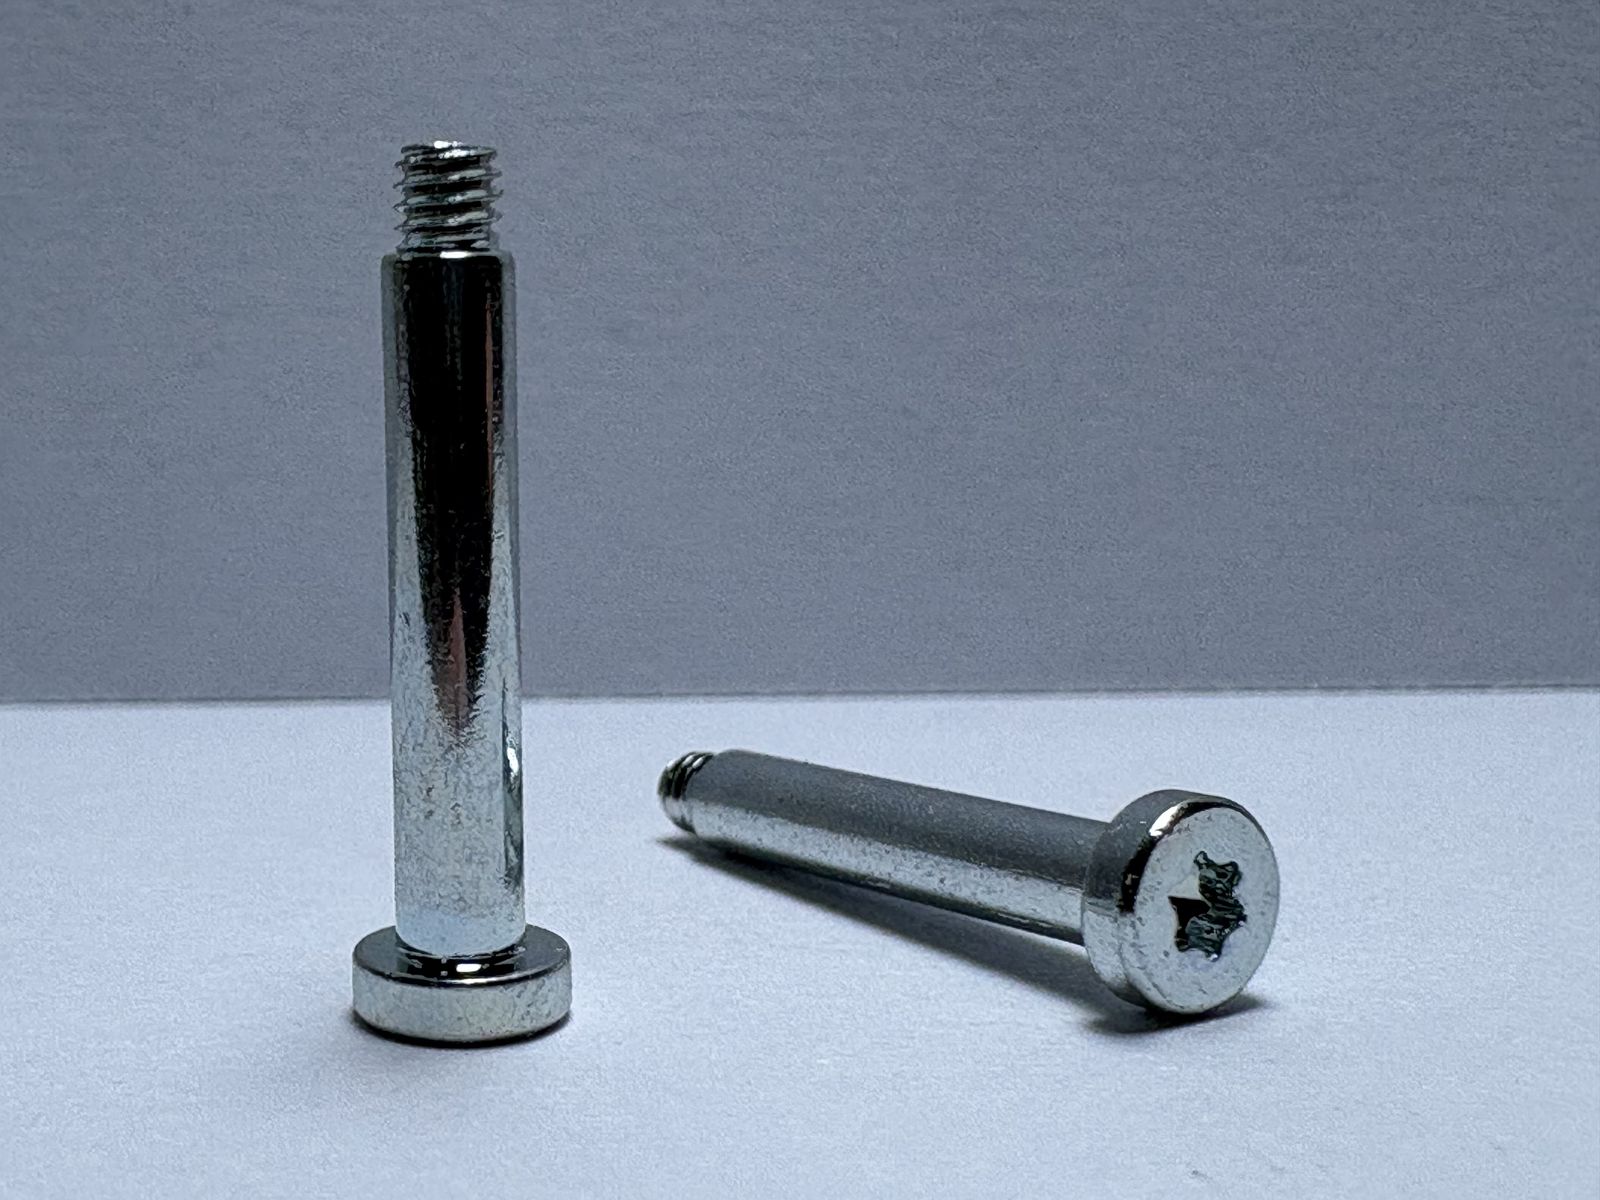
Precision Components · Ø1.0 – Ø10 mm
Shoulder Screws & Pins
Precision shoulder screws, dowel pins and stepped pins ground to h9 for pivot, locating and alignment duties in miniature mechanisms.
h9 ground shankPivot & locatingStainless / alloy
Industry
Fasteners for harmonic drives, cycloidal reducers and frameless motors
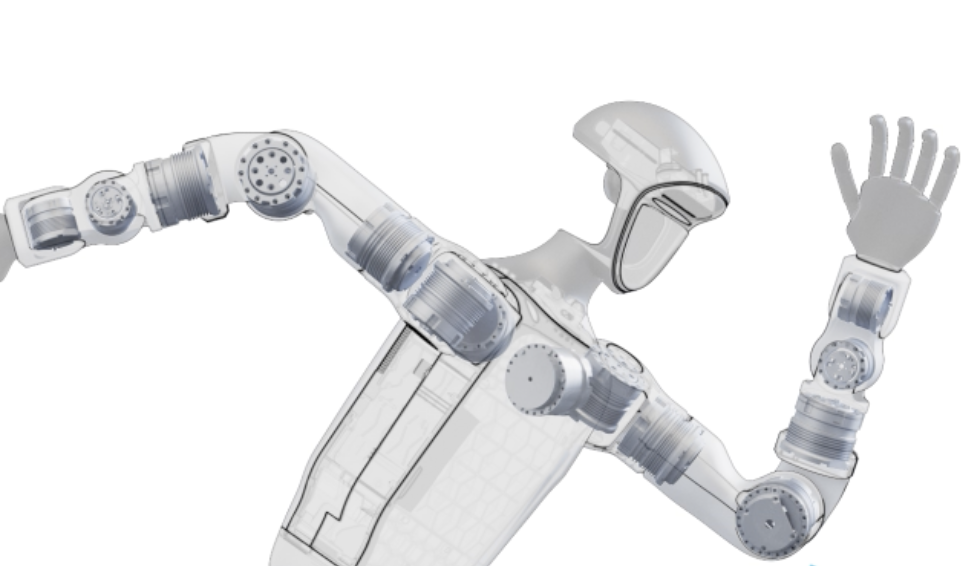 Joint Actuators & Drives
Why it matters
A robot joint module packs a frameless motor, a harmonic or cycloidal reducer, an encoder and a brake into a cylinder the size of a fist. The fasteners have to clamp the reducer flexspline without distorting it, retain the rotor against torque reversal, and locate the encoder ring to within a few micrometres — all while the module heats to 70 °C in continuous duty.
We supply socket head and low-profile screws in 10.9 and 12.9 for reducer and housing joints, ground dowel pins for locating, and precoated screws for positions that see torque reversal. Because joint modules are usually assembled in small batches, we support lower volumes with the same documentation as high-volume electronics work.
M2 – M5
Joint module fastener range
12.9
Reducer clamp property class
h6
Locating pin fit available
70 °C
Continuous duty housing temperature
Field problems
These are the failure modes we see most often, and the engineering response that addresses each one. Problems are stated as they appear on the line, not as they appear in a textbook.
| Problem observed | Engineering response |
|---|---|
| Clamping the flexspline distorts it and increases transmission error. | Controlled preload with a specified torque and friction coefficient, plus flatness-checked washers to spread load. |
| Torque reversal loosens the reducer housing screws. | Encapsulated adhesive on 12.9 screws, with break-loose torque verified after a reversing-duty cycle test. |
| The encoder ring shifts and the zero position drifts. | Ground h6 dowel pins locating the ring to the housing, with position tolerance stack reviewed at design stage. |
| Aluminium housings creep under sustained preload at 70 °C. | Steel inserts or through-bolted joints, with relaxation data at temperature rather than room temperature. |
| A small batch of 200 joints does not justify a custom screw. | Standard diameter families with modified lengths and heads from existing tooling, at low minimum order. |
| The module must be non-magnetic for a collaborative robot. | SUS316 and titanium fasteners with permeability certification, and non-magnetic dowel pins. |
Specification basis
A starting specification, not a fixed menu. Most programmes adjust one or two of these after the first joint review.
Diameter
M2.0 – M5.0
Property class
10.9, 12.9, A4-80
Head style
Socket head, low profile, countersunk
Locating pins
h6 / h7 ground, straightness 0.01 mm/10 mm
Locking
Encapsulated adhesive for reversing duty
Temperature
Continuous 70 °C, peak 100 °C
Runout
≤ 0.02 mm on rotor retention faces
Documentation
Material cert, torque spec, relaxation data
Recommended products
Chosen for the tolerance, finish and locking requirements typical of the assemblies described above.
Precision Components · Ø1.0 – Ø10 mm
Precision shoulder screws, dowel pins and stepped pins ground to h9 for pivot, locating and alignment duties in miniature mechanisms.
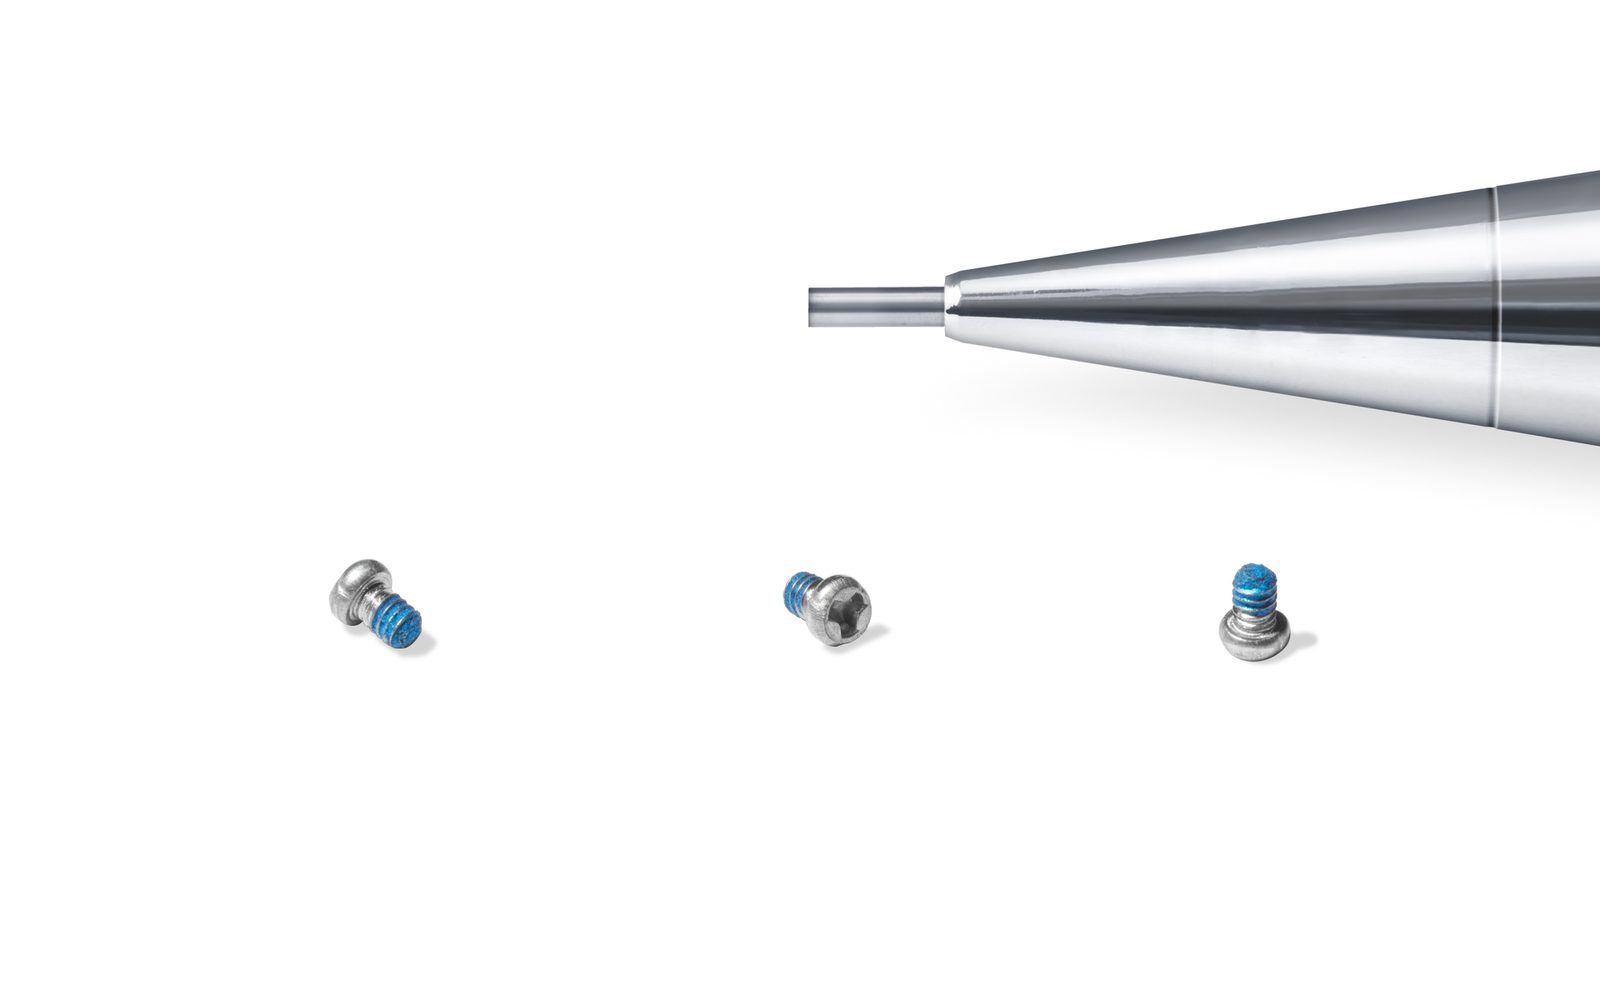
Micro Screws · M0.8 – M6
Screws with a factory-applied locking or sealing element, so the assembly line receives a ready-to-drive fastener with no liquid adhesive and no cure time.
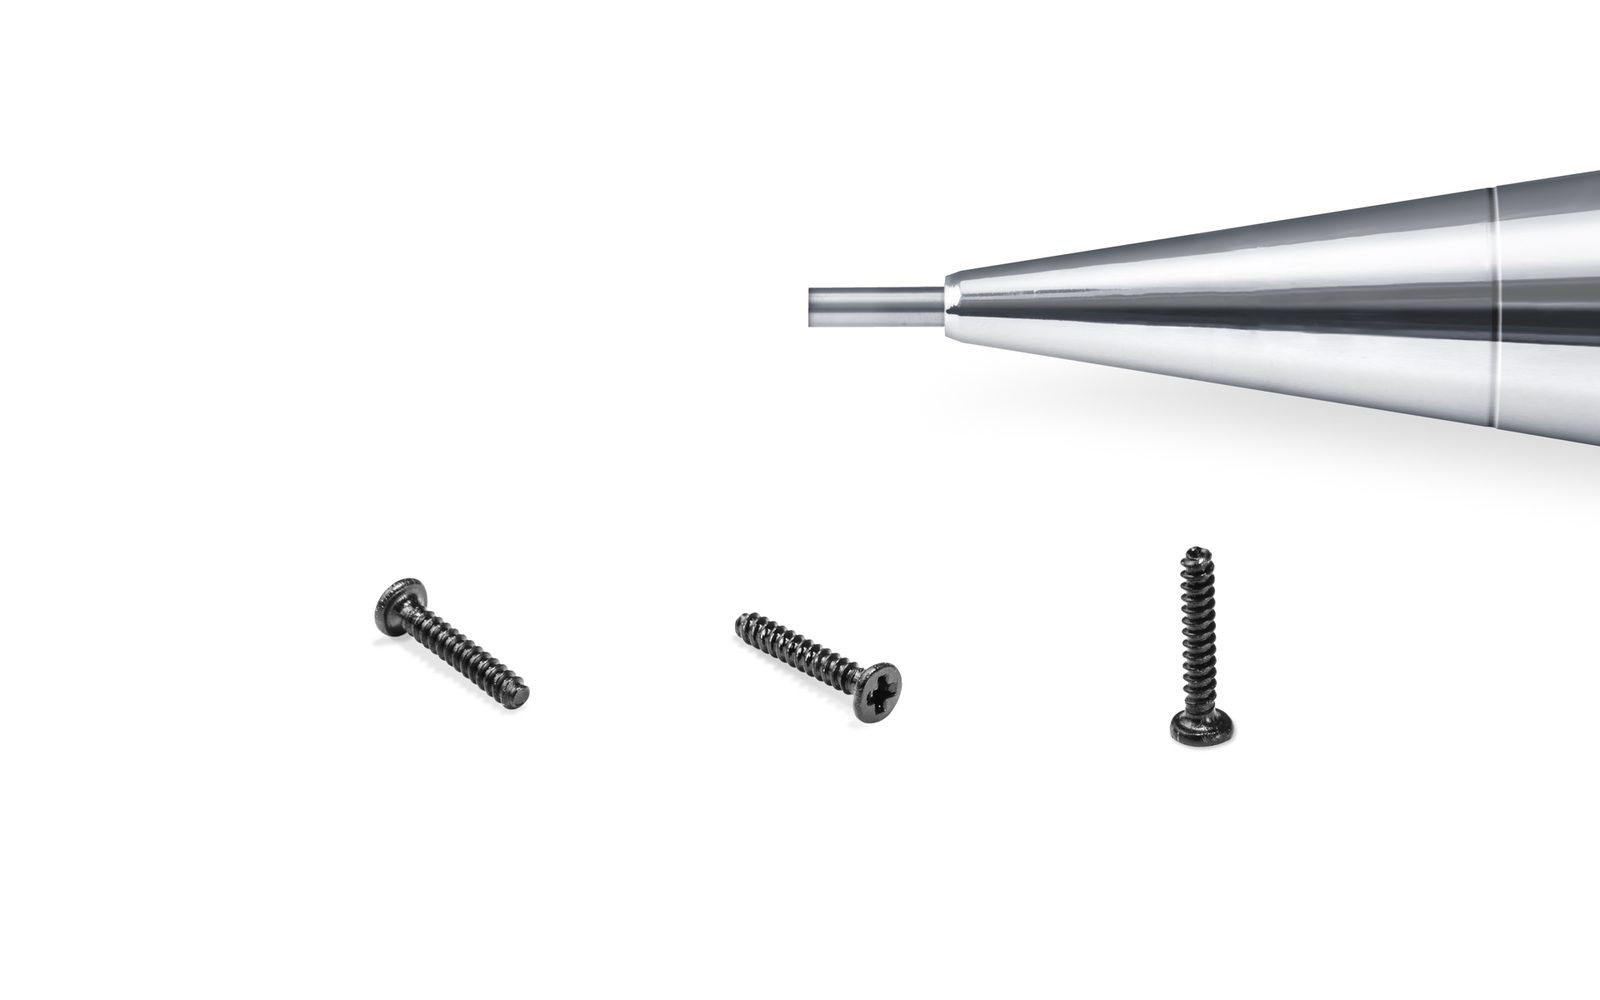
Micro Screws · M0.5 – M6
Precision machine screws from M0.5 to M6 with rolled Class 6g threads, tight head concentricity and clean drive recesses for automated driving.
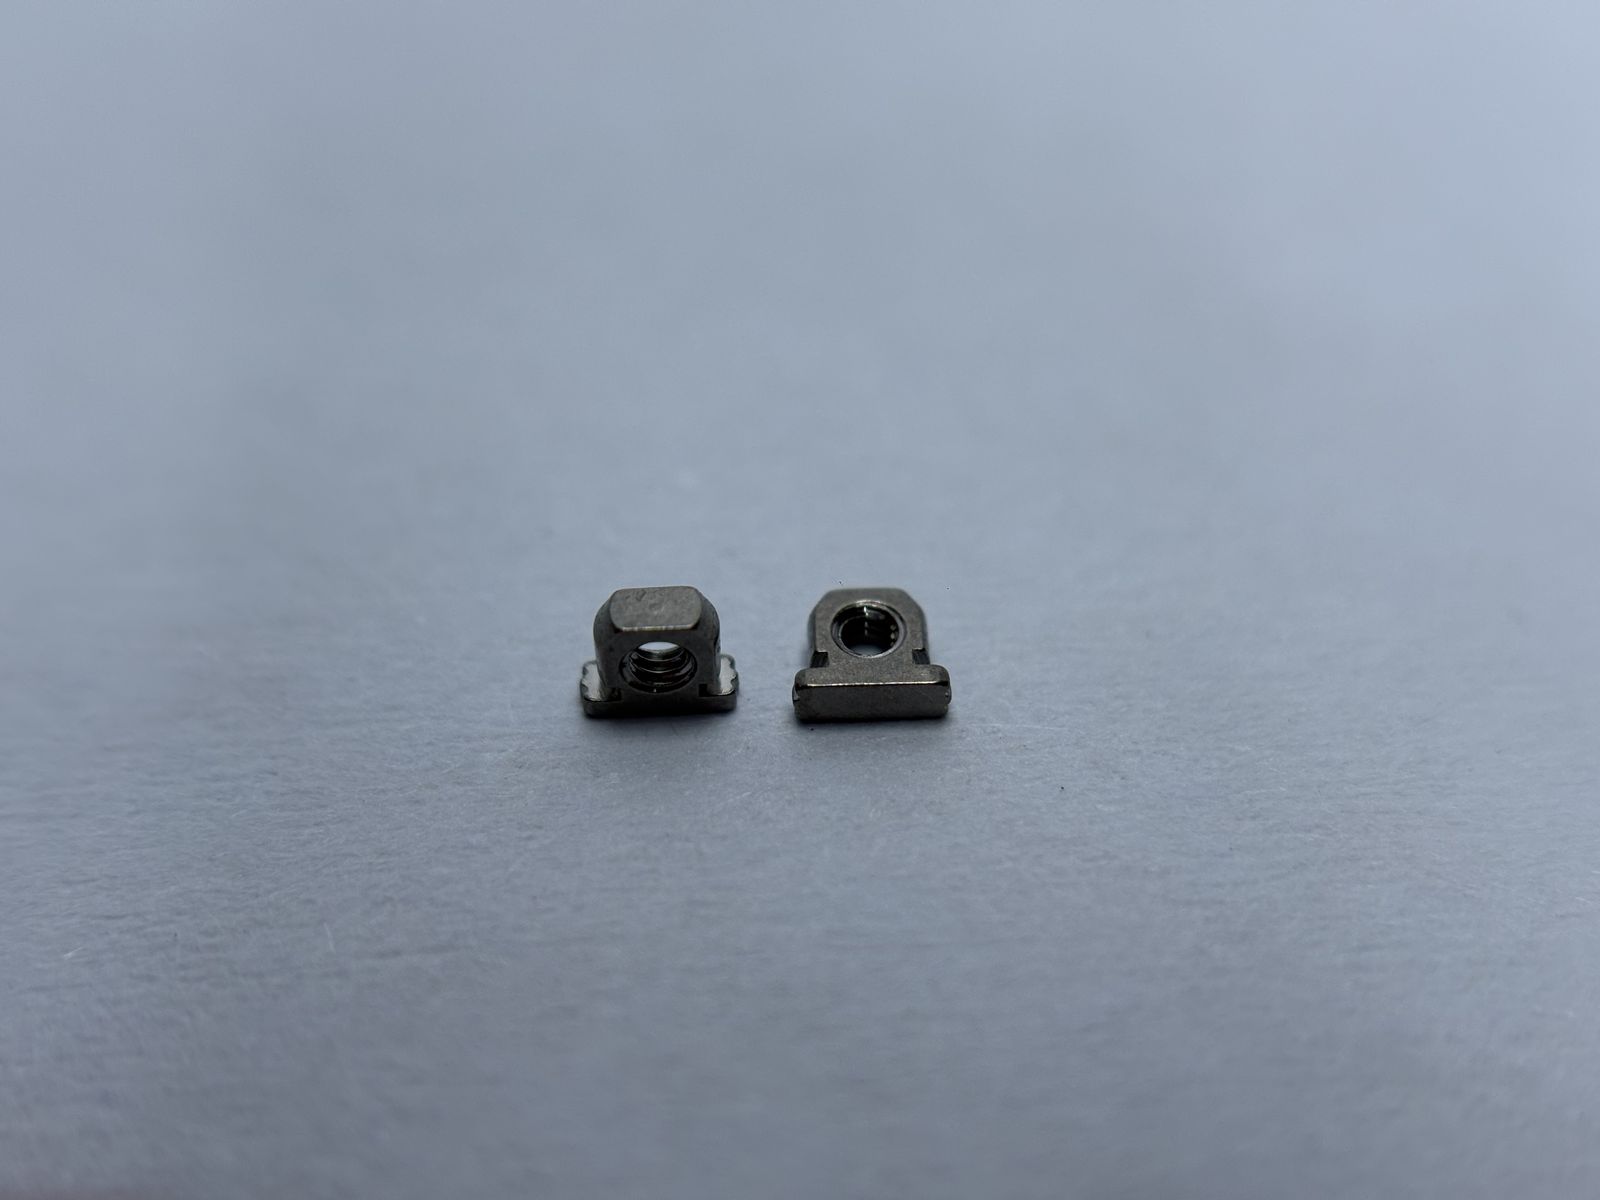
Precision Components · M1 – M4
Male-female and female-female standoffs from M1 to M4, plus plain spacers, in brass, stainless and aluminium — with length tolerances that keep board stacks parallel.
Design notes
These decisions are cheap at concept stage and expensive after tooling is cut.
01
The bolt circle stiffness affects transmission error. A higher property class helps, but a shorter grip length and a stiffer flange usually help more.
02
Do not rely on screw clearance to locate an encoder ring. Use dowel pins for position and screws only for clamp load — mixing the two functions wastes both.
03
Aluminium loses preload faster at 70 °C than at 20 °C. Ask for relaxation data at operating temperature if the joint is safety-relevant.
04
Joint modules ship in hundreds, not millions. We support low minimums with standard tooling and modified lengths rather than requiring a new die.
Joint review
A drawing gives us geometry. The mating material, the service cycles and the cleaning chemistry decide whether the joint works. Send all three and we will review the whole stack.
Questions
Answers to the questions that come up most in this industry.
Related industries
The same fastener discipline applies across these industries, with different documentation and validation requirements.
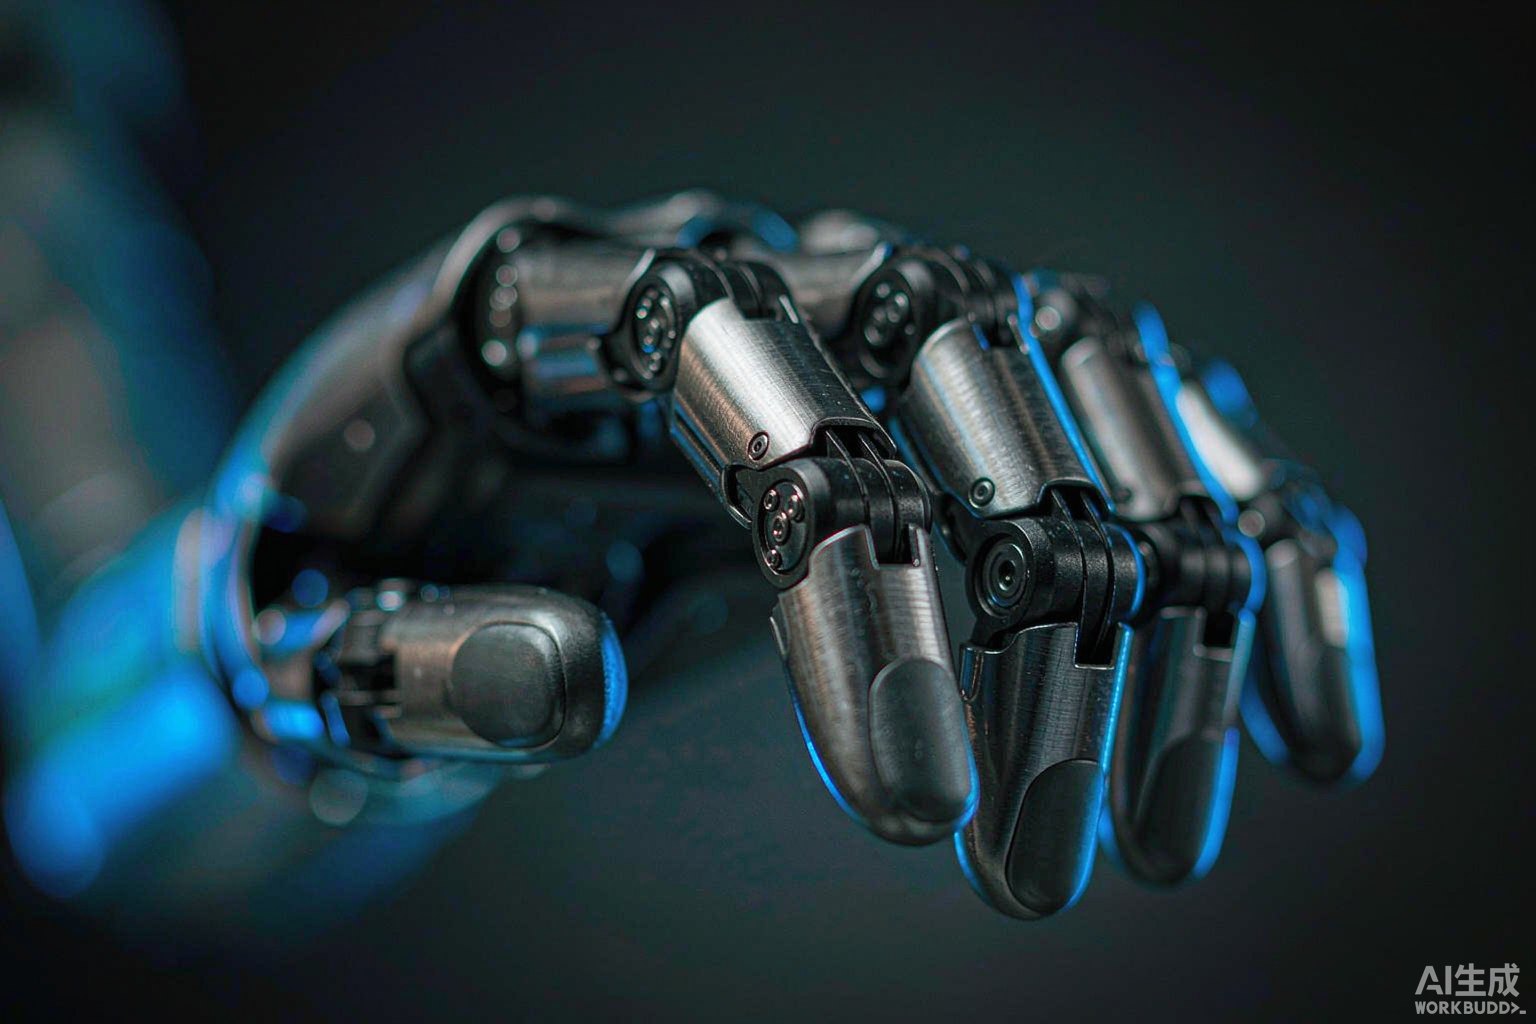
Industry
Our second focus industry: M1–M4 high-strength fasteners for dexterous hands, finger linkages and tendon-driven mechanisms, where fasteners see millions of cycles.
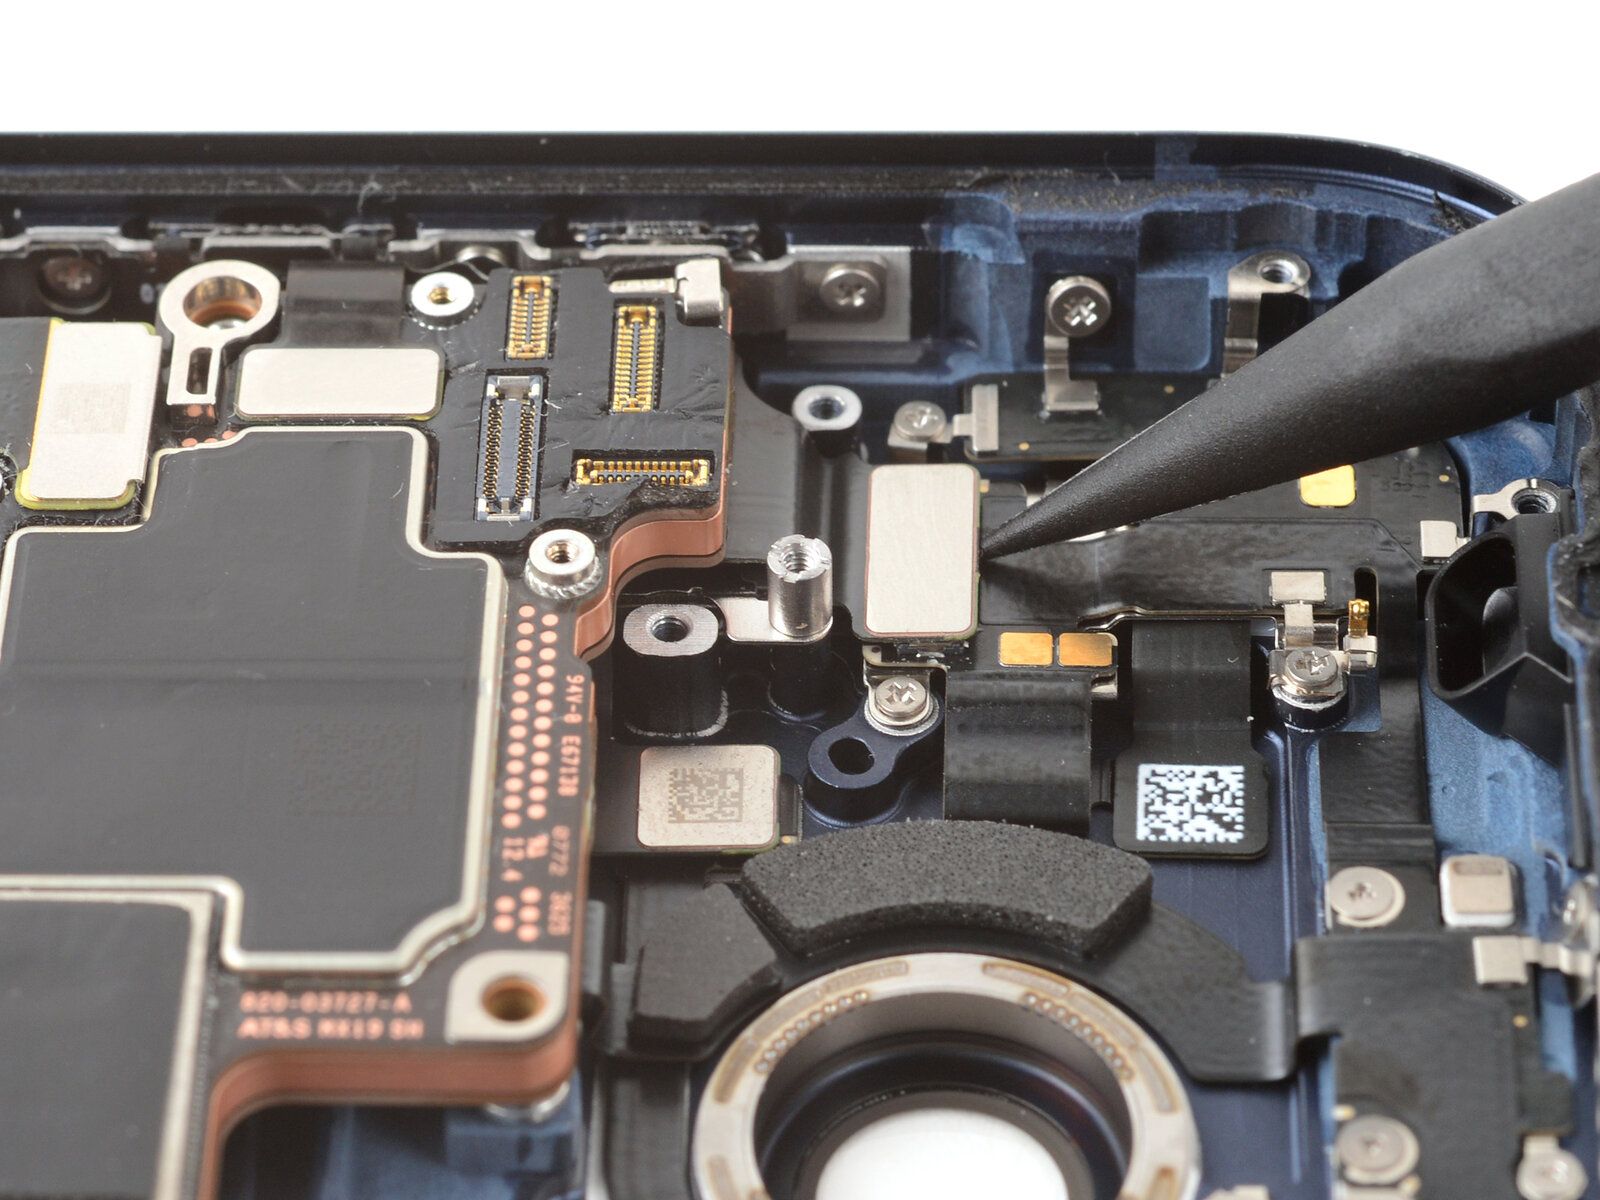
Industry
The core of our business: M0.5–M3 fasteners for smartphone modules, notebooks, wearables and PCB assemblies, with the finish control that cosmetic electronics demand.
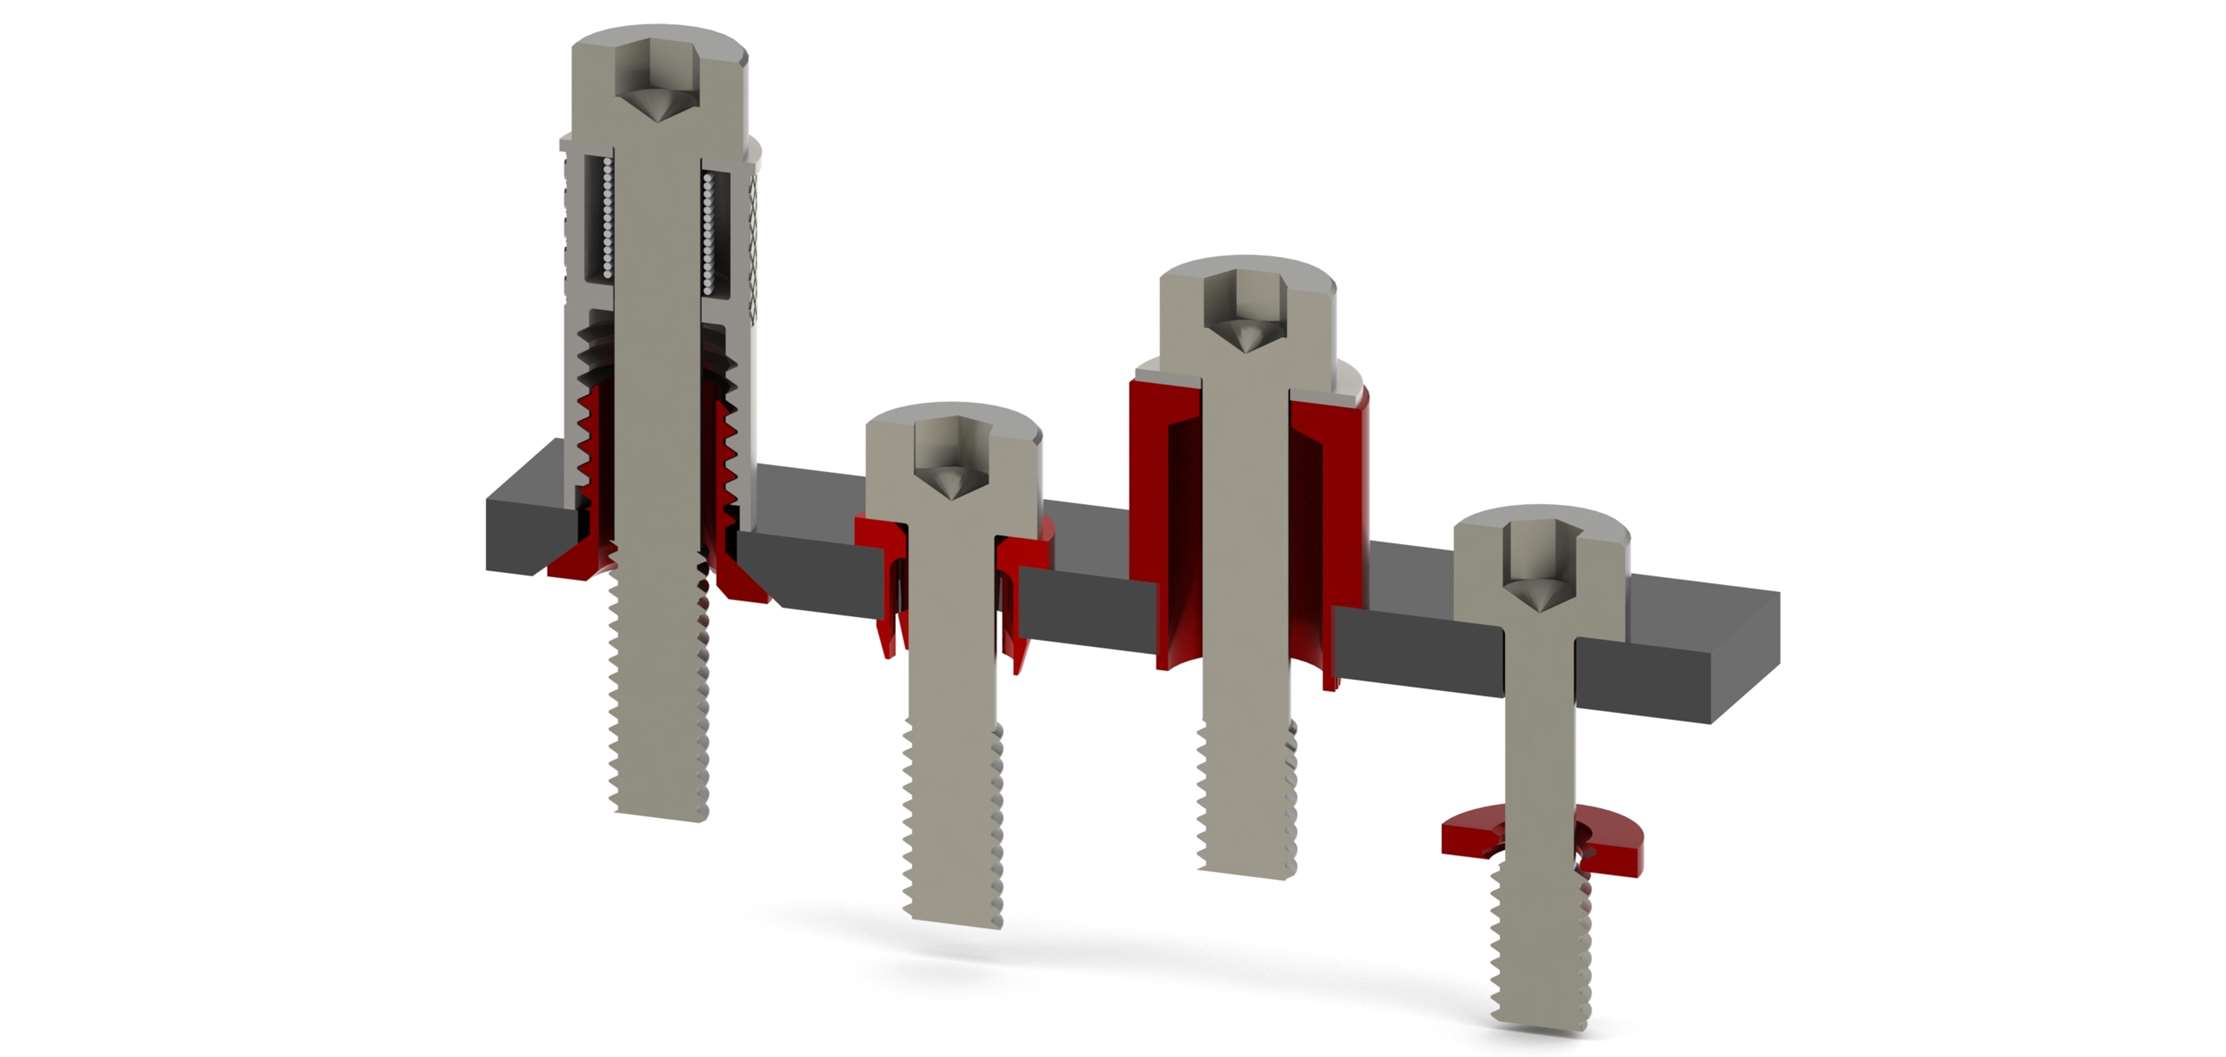
Industry
Automotive-grade micro fasteners with PPAP, traceability and vibration validation for control units, sensor housings and battery management systems.
Industry
Stainless and titanium micro fasteners for surgical instruments, diagnostic equipment and analytical instruments — cleanable, non-magnetic and documented.
From a single prototype joint to a PPAP production launch, the same team reviews the drawing and the assembly context.